Top, Professional and Reliable Manufacturer of Various Machinery – YG Machinery
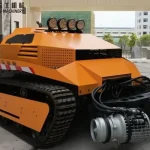
Intelligent Concrete Vibration Robot
construction concrete vibration robot
remote-controlled concrete vibration robot
On a big floor slab, concrete vibration is usually done by workers moving a heavy poker rod point to point by hand. That walking is repetitive and tiring, and it creates two risks: the depth and spacing of each insertion can drift as the day goes on, and the vibration cycle may not keep up with the pace of the concrete supply.
This is not a statement that all manual vibration is low quality. Experienced crews do good work. The point is that on large, repetitive, shallow-layer slab pours, manual vibration asks the same person to control depth, spacing, speed, and timing for hours — which is hard to keep uniform.
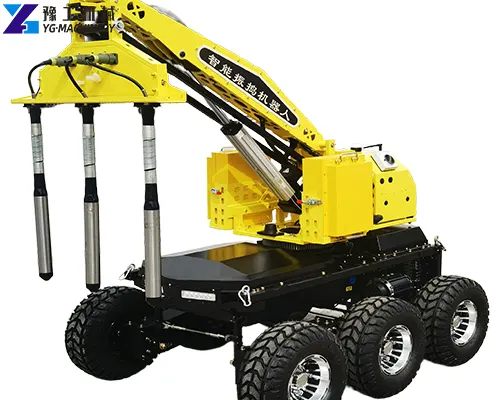
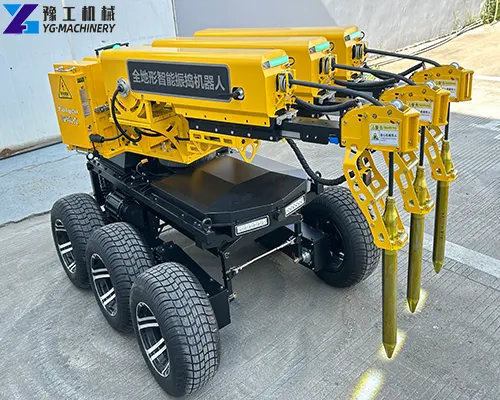
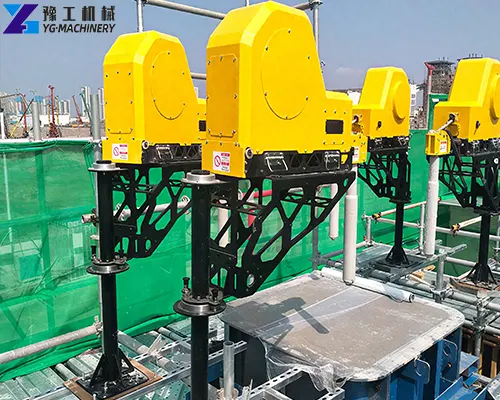
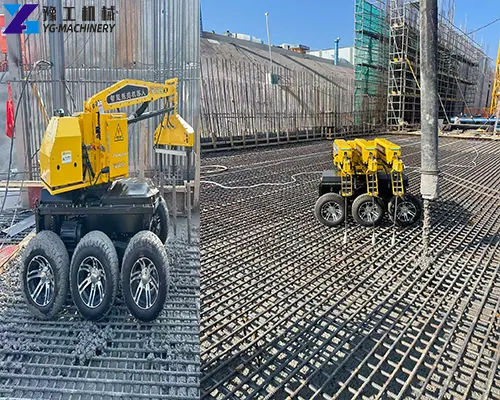
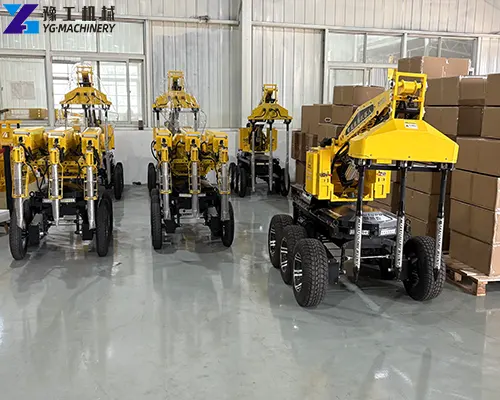
An intelligent concrete vibration robot is an electric, automated system that takes over that repeated cycle: insert, vibrate, lift, and move to the next point, at a set depth and spacing. It is built for base slabs, intermediate slabs, roof slabs, and other large-area shallow-layer vibration.
What Buying This Robot Really Buys You
The touch screen, APP, automatic fixed-distance mode, and the six-step cycle are not features to list — they solve four practical problems:
Fewer repeated manual actions. The robot travels, rotates, lowers, vibrates, lifts, and moves by itself, so the operator supervises instead of walking and inserting by hand.
More consistent point placement and insertion. Automatic fixed-distance mode keeps the spacing and depth repeatable across the pour. “Precision” here means a repeatable, programmable process, not a claimed millimeter tolerance that we do not state.
Easier shift organization. With remote control and a battery, the operator can plan who supervises the machine, not how many people walk the slab.
A defined working cycle. The six steps — rotate to position, lower to preset depth, vibrate at controlled frequency, lift, reset, and move — are executed in the same order every time.
How the Automated Cycle Works
Each vibration point follows the same sequence:
Rotation of the vibration rods to the target position
Lowering of the rods to the preset depth
Vibration at the controlled frequency
Lifting of the rods
Reset rotation
Travel to the next point
Repeating this cycle with fixed spacing and depth is what improves consistency on repetitive work. The depth is set to match the slab; the spacing comes from the automatic fixed-distance logic.
View the Specifications Table for YG’s Intelligent Concrete Vibrating Robot
Parameter
YG3100
YG3500
Overall dimensions
191 × 118 × 118 cm
118 × 175 (215) × 117 cm
Rotation diameter / Coverage width
1910 mm (rotation diameter)
300 cm (vibration coverage width)
Standard vibration depth
1500 mm (customizable)
500 cm (customizable)
Chassis ground clearance
300 mm
30 cm
Machine weight
418 kg
485 kg
Rated load
150 kg
150 kg
Control method
Wireless remote control
Wireless remote control
HMI system
7-inch touch screen + vibration APP
7-inch touch screen + vibration APP
Emergency stop
Front & rear emergency buttons
Front & rear emergency buttons
Alarm system
Audible & visual alarm
Audible & visual alarm
Vibration rod diameter
50 mm
50 mm
Vibration diameter
100 cm
100 cm
Rod length
40–50 cm
40–50 cm
Frequency range
100–200 Hz
100–200 Hz
Speed control
Stepless, max 12,000 rpm
Stepless, max 12,000 rpm
Battery power
8.4 kW
8.4 kW
Rated voltage
72 V
72 V
Battery capacity
113 Ah
113 Ah
Charge cycles
≥ 1200
≥ 1200
Working time
Up to 12 hours
Up to 12 hours
Typical application
Standard slabs, deeper vibration depth
Large-area slabs, wider coverage
Selecting the Right Model for Your Job
Before choosing YG3100 or YG3500, work through these site questions:
Does the slab thickness match the rod length and insertion depth? Rod length is 40–50 cm. Confirm the actual thickness and required insertion depth against the approved method; a deeper structural element may not fit this robot.
Do rebar, columns, or pump lines break the travel path? The robot moves across the slab; fixed obstacles can prevent automatic fixed-distance travel. Check whether the layout allows continuous passes or needs manual mode around obstacles.
Can the battery-swap design match your shift schedule? For continuous work, plan the battery change points against your pour rhythm. Confirm the swap and charging plan (not a fixed output claim) with YG.
Can the work surface carry the machine weight? 418–485 kg on a fresh or green slab, formwork, or a finished floor — verify floor load and early-age concrete conditions before running.
How is the method confirmed? Use a representative trial area to set the vibration depth, spacing, and the concrete mix’s required time, and record it as the working procedure before full pours.
These practical project checks help you confirm whether an intelligent concrete vibration robot fits your scope before quotation.
Slab thickness matching with probe length and insertion depth. Probe length (40‑50 cm) sets hard physical limits for practical insertion depth. Your target slab thickness must align with usable probe immersion length. Custom depth options are available, subject to YG technical review.
Site layout obstructions: Rebar clusters, embedded columns, pump‑pipe runs and formwork edges can block robot travel and probe movement. Map obstacles on your pouring layout to identify zones where automated cycles cannot run. These areas will still require supplementary compaction work.
Battery‑swap capability and multi‑shift planning. Swappable probe batteries support shift hand‑over without full‑machine shutdown. Confirm battery stock, charging space on‑site, and your actual working‑hour schedule. Runtime and charging values are to be verified against official documentation.
Slab surface load‑bearing capacity. Check that the finished or temporary base surface can safely support the machine operating weight (418 kg / 485 kg). Soft sub‑base, uneven mud, or un‑compacted fill may restrict robot mobility.
Project validation via test area. For new‑type applications, YG recommends running a representative small test section. Validate cycle settings, probe insertion, concrete response, and obstacle handling before full‑scale pouring.
A Complementary Option: Excavator Vibrator Attachments
For regular, accessible, large-area slab work, the robot provides a more automated approach to repeated positioning and vibration.
For suitable deep zones or complex structures, YG also offers excavator concrete vibrator attachments in four-, six-, and eight-rod arrangements; other quantities require customization.
Dense reinforcement does not automatically favor either solution. Every arrangement still needs insertion-clearance and positioning checks. Excavator attachments additionally require carrier, hydraulic, mounting, and operating-radius verification.
A combined plan may be more practical than choosing one machine for every area: use the robot for suitable repetitive zones and approved supplementary equipment for restricted locations.
Frequently Asked Questions About Intelligent Vibration Robots
Q1: What types of projects suit an intelligent concrete vibration robot?
It is optimized for large‑area regular‑geometry shallow pours: factory floors, building intermediate slabs, podium slabs, and roof decks. Obstacles such as dense columns or heavy embedded hardware create zones requiring supplementary manual compaction.
Q2: What is the difference between YG3100 and YG3500?
YG3100 works by rotating‑arm coverage (1910 mm rotation diameter). YG3500 delivers wider linear vibration coverage (3000 mm). Coverage metrics use different measurement logic and cannot be directly compared. Probe length and core control features are similar for both models. Runtime and depth limits must be confirmed from official datasheets.
Q3: Can I adjust vibration depth for different slab thickness?
Yes, vibration depth is customizable, but physical probe length sets practical limits. Submit your slab‑thickness drawing for YG technical assessment.
Q4: Does the robot replace all manual concrete compaction work?
No. Column perimeters, rebar‑congested zones, and areas blocked by pump piping or formwork will still need supplementary compaction. It improves repeatability on open slab sections, not every single location on‑site.
Q5: When should I pick an excavator‑mounted vibrator instead of this robot?
Choose excavator‑mounted concrete vibrator attachments for deep foundations, pile caps, or heavily obstructed, irregular work zones where pre‑programmed robot travel paths are not feasible.
Q6: What documents should I prepare to get a formal technical proposal?
Submit slab drawings including thickness, rebar layout, obstacle locations, concrete mix‑type, pouring shift schedule, site surface‑load conditions, and target compaction requirements.